Mobile manipulation platforms for research: lift, head and base control explained
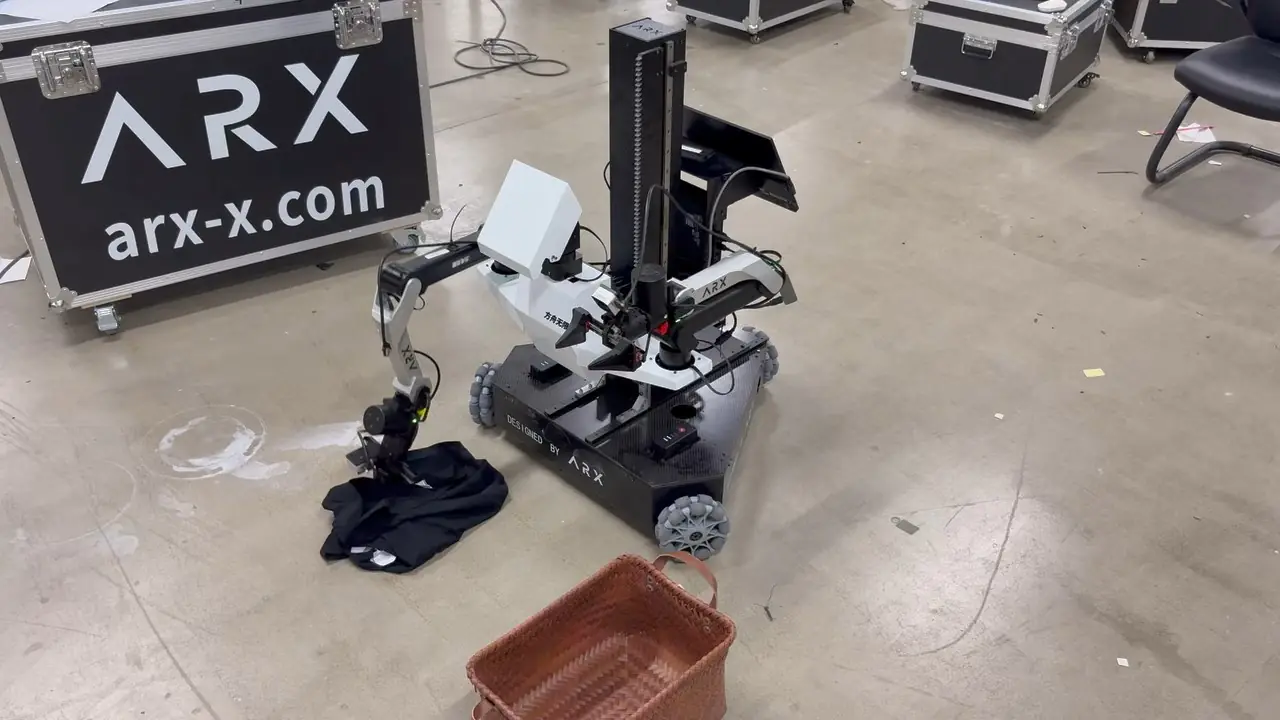
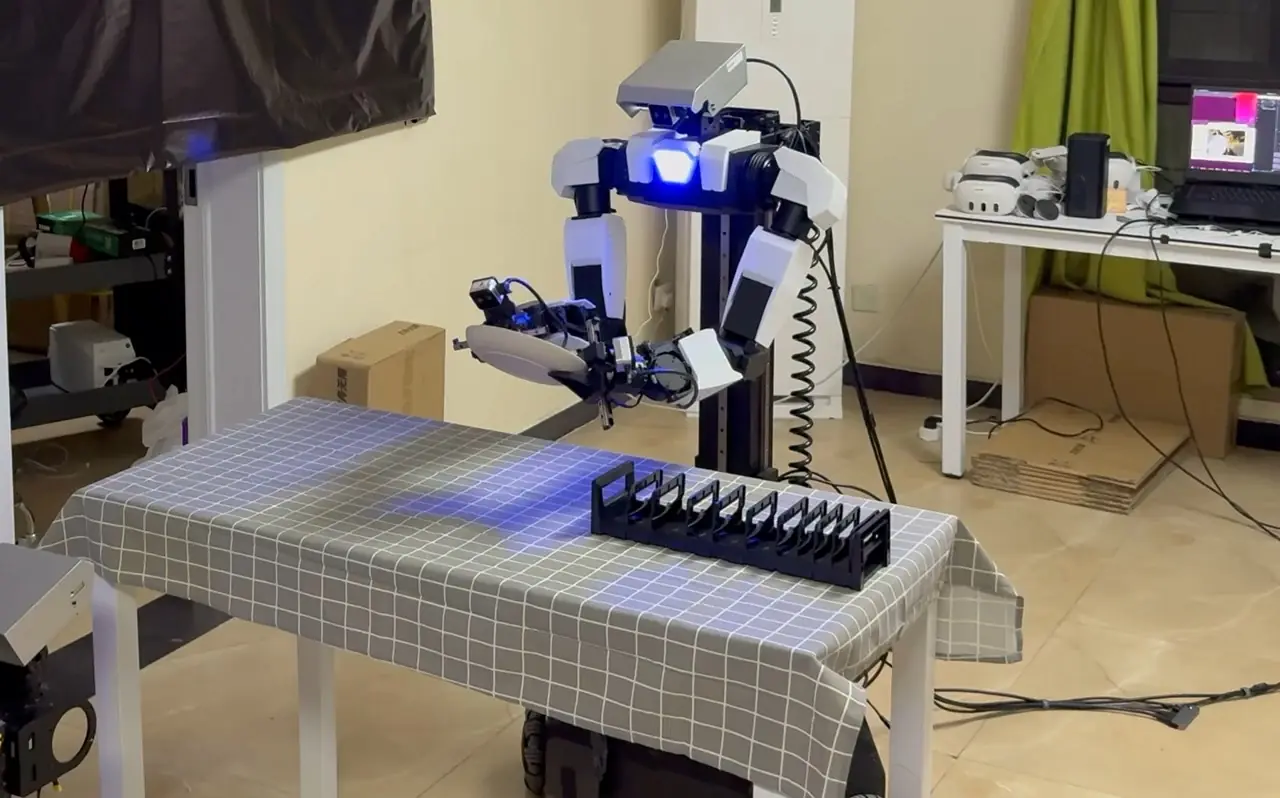
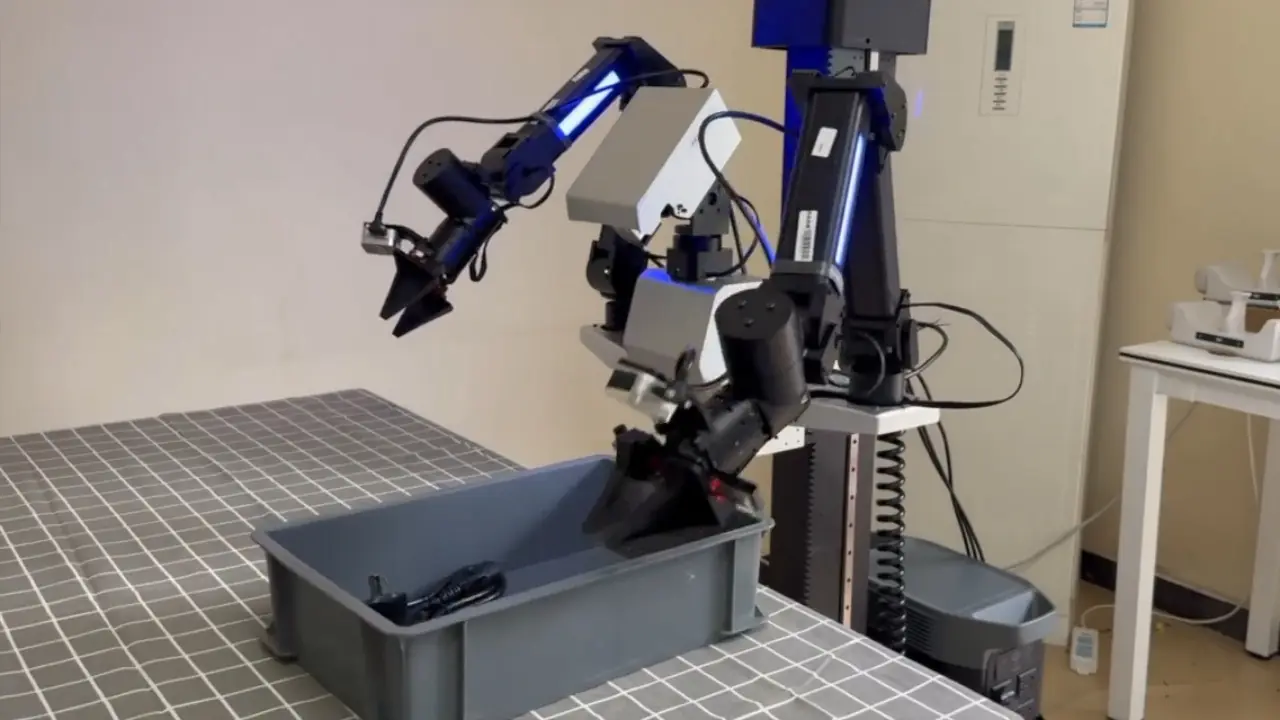
Short answer: a research mobile manipulator is two arms on a wheeled base, plus three things a tabletop station does not need: a lift to change working height, a head camera you can point, and teleoperation that works while the robot moves. It should also run the same collect–train–deploy pipeline as your tabletop stations. ARX's LIFT2s and X7s expose all of these through ROS 2.
The five things to check
| Need | Why | On ARX LIFT2s and X7s |
|---|---|---|
| Base drivable from code | Policies and scripts move the robot | ROS 2 topic /body_control; feedback on /body_information |
| Lift column | Tasks happen at different heights | Height set in software, can be fixed during collection and inference |
| Movable head camera | The camera must see the hands | Head pose set in radians |
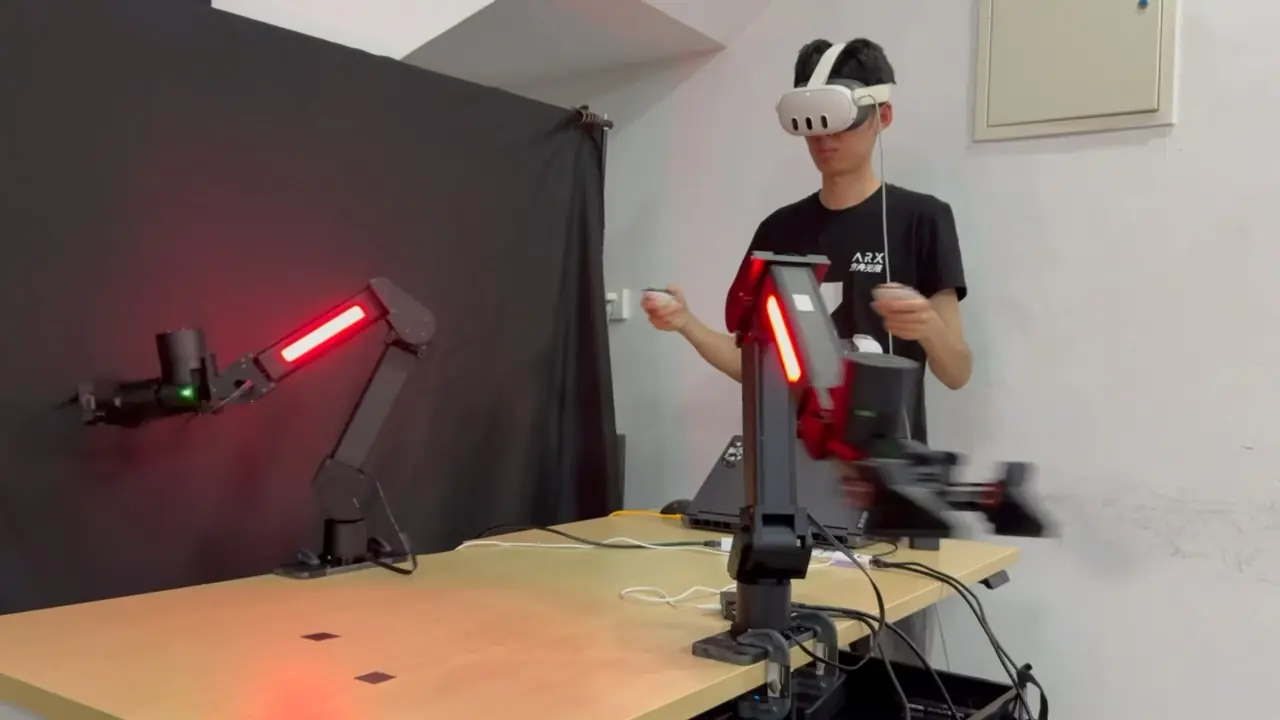
| Teleoperation on the move | Operators drive, look and manipulate | VR teleoperation |
| Same pipeline as tabletop | One training stack for all data | ARX ROS 2 collect → train → deploy |
Dual-arm platform or humanoid?
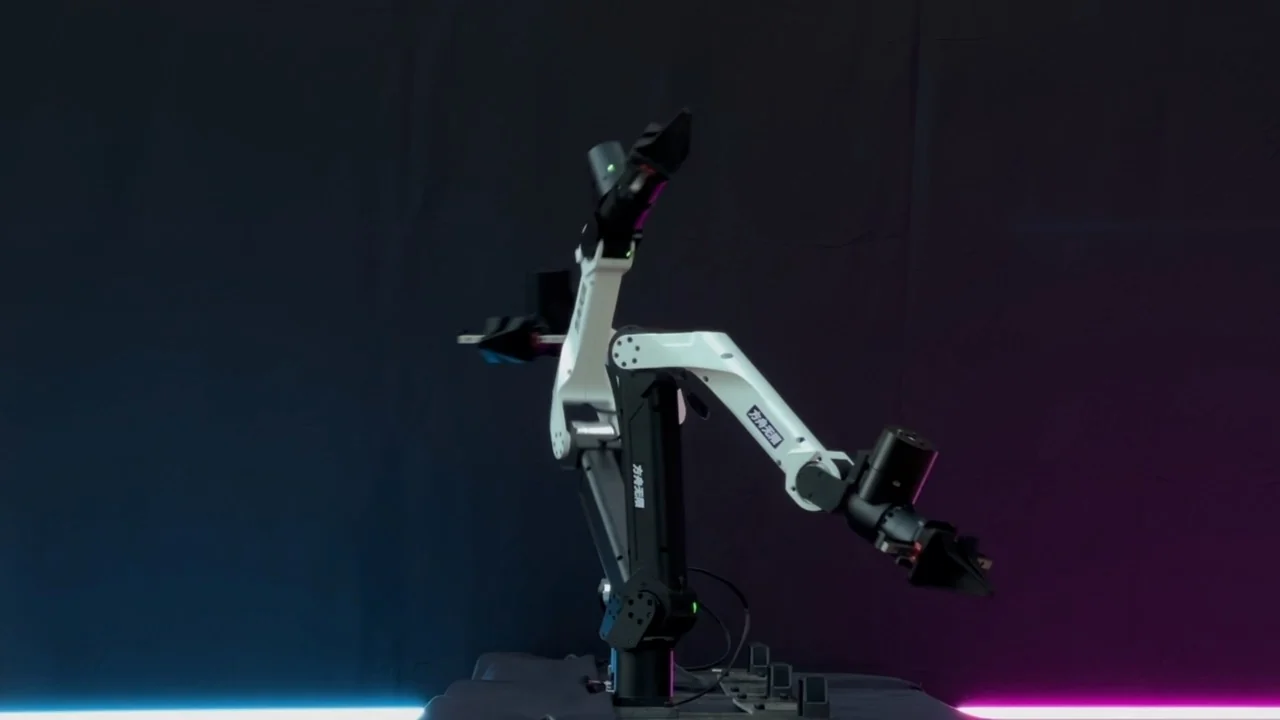
- LIFT 2 is a wheeled dual-arm platform with a lift column. Choose it when you want two arms that work at table height and below, on a simple mobile base.
- X7 is a wheeled humanoid with two arms. Choose it when a humanoid upper body matters for your research or demonstrations.
Both run the same ROS 2 software in their LIFT2s and X7s versions, so data and code carry over. The first-generation LIFT also works with the pipeline in its X5-based version; the older R5-based LIFT does not.
Recording tips for mobile tasks
- Fix the lift while you learn the arms. ARX documents how to hold a fixed height during collection and inference. Add height as a variable later.
- Map cameras to head, left and right by serial number. ARX's camera script lists each RealSense camera so you can assign it.
- Mind the emergency stop and the lift. Release the emergency stop before starting. ARX warns that the lift drops when power is cut, so keep hands and objects clear.
- Separate robots on the network. Give each robot its own
ROS_DOMAIN_ID.
Related work
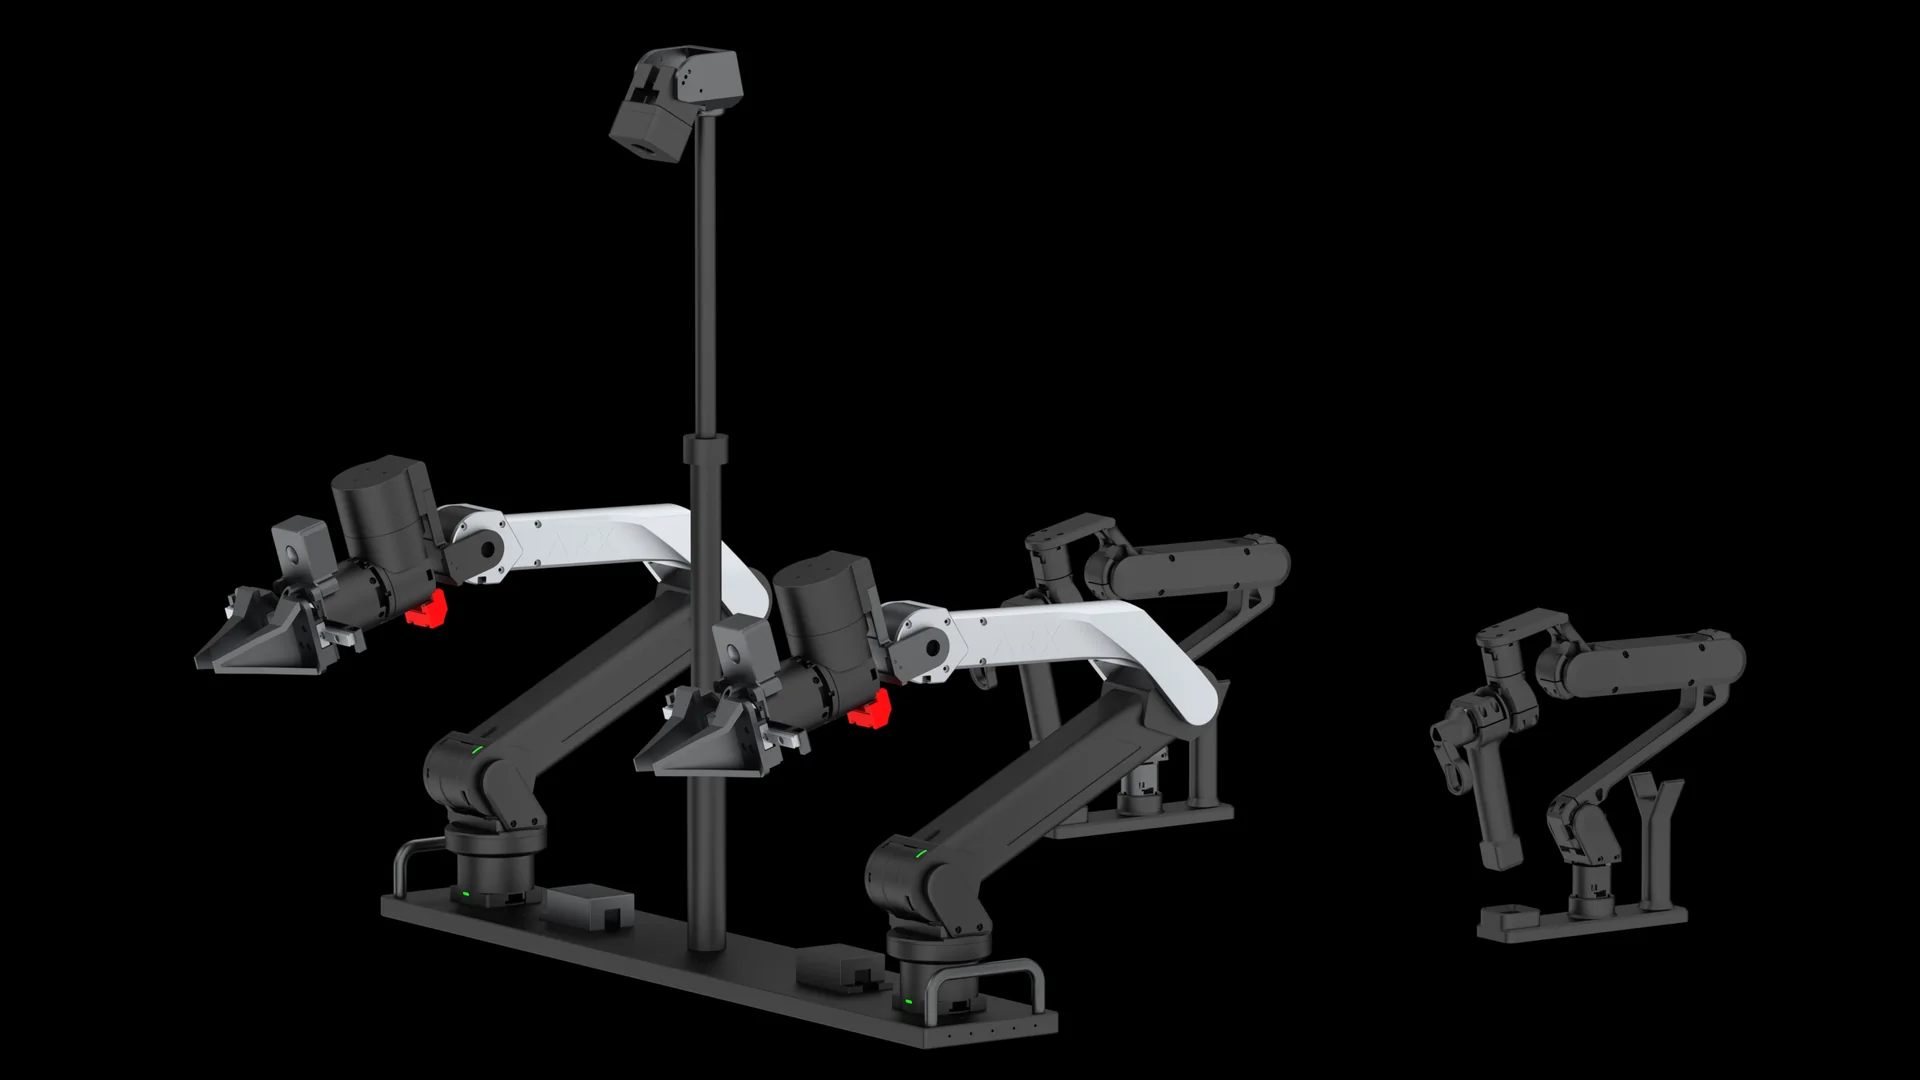
ModPack (Stanford, 2026) is an open-source backpack teleoperation framework for two-armed mobile robots. It uses ARX5 leader arms that are kinematically equivalent to the follower arms (ModPack).